PTV and rFpro connect traffic co-simulation for ADAS HIL
PTV Vissim and rFpro now exchange closed-loop vehicle and traffic state for real-time ADAS HIL and DIL validation scenarios.
Summary
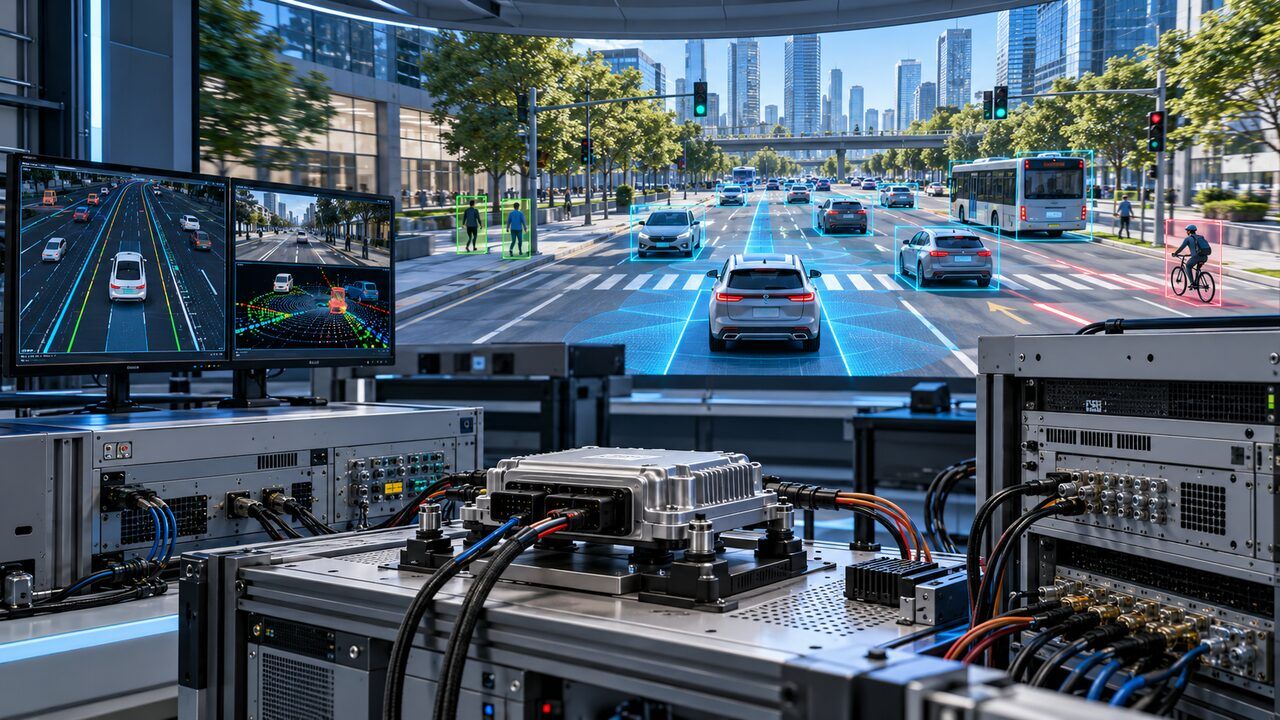
PTV Group and rFpro have integrated PTV Vissim traffic simulation with rFpro’s driving-simulation environment for ADAS and automated-driving validation. Their setup uses a shared road network and coordinate system through ASAM OpenDRIVE, while PTV Vissim’s Driving Simulator Interface exchanges vehicle position, speed and orientation in closed loop.
Supplier claim
The companies say the integration supports real-time HIL and driver-in-the-loop testing, allowing an ego vehicle in rFpro to interact with traffic, pedestrians, cyclists and signals generated in Vissim. They also position the same scenarios for training-data generation. No independent performance or correlation results were published in the announcement.
Bench-selection questions
For procurement, ask for demonstrated end-to-end latency, deterministic update rates and supported HIL interfaces on your target bench. Check how road-network changes, scenario seeds and traffic behavior are versioned; how sensor outputs are synchronized; and which failure modes are detectable. Request correlation evidence against your proving-ground data before relying on the co-simulation for safety-related validation.
Evaluating a HIL system or automotive software?
Discuss your requirements, supplier options, or a quotation with Simitro.
Discuss your requirement